
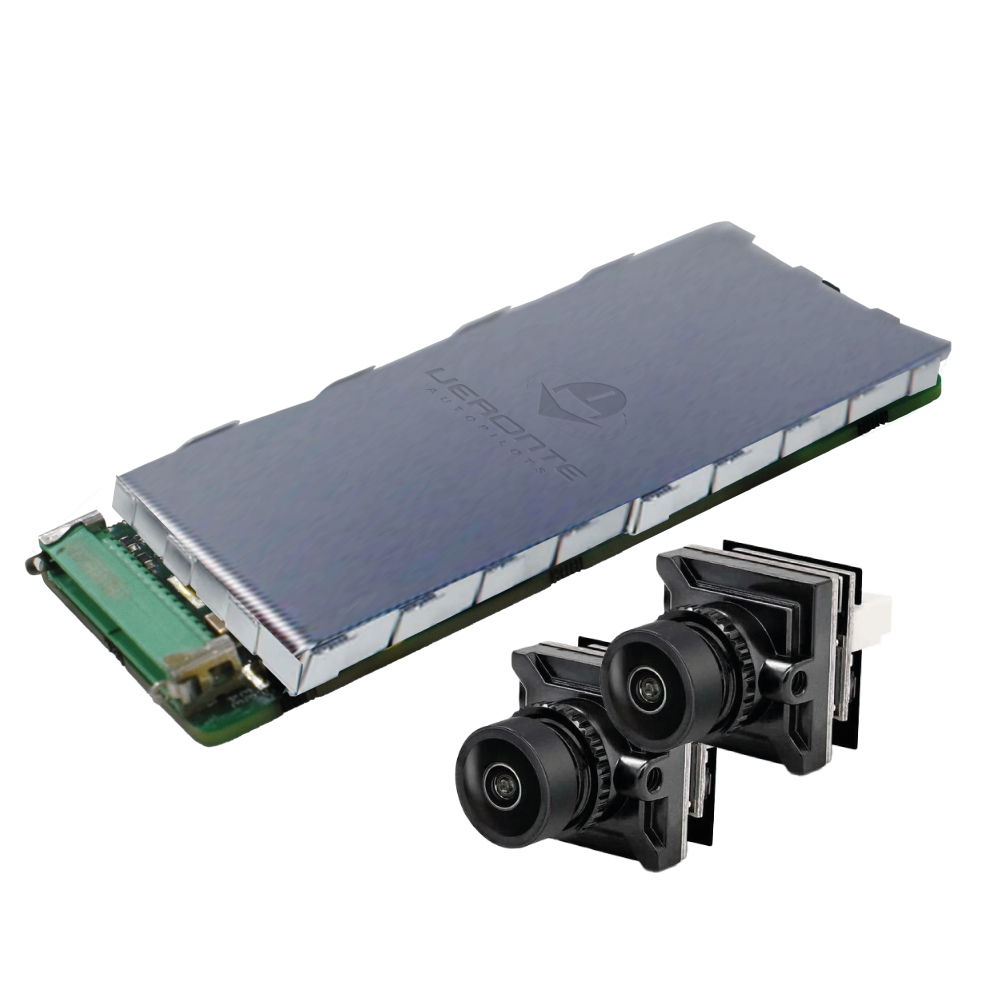
Autopilots LM
FCS for Loitering Munitions.
Cutting-edge autopilot system tailored for Loitering Munitions. This cost-effective solution combines flight control with advanced computer vision technology, enabling precise navigation and target tracking even in GNSS-denied operations.
Autopilots LM
FCS for Loitering Munitions.
Cutting-edge autopilot system tailored for Loitering Munitions. This cost-effective solution combines flight control with advanced computer vision technology, enabling precise navigation and target tracking even in GNSS-denied operations.
Wiring Optimization
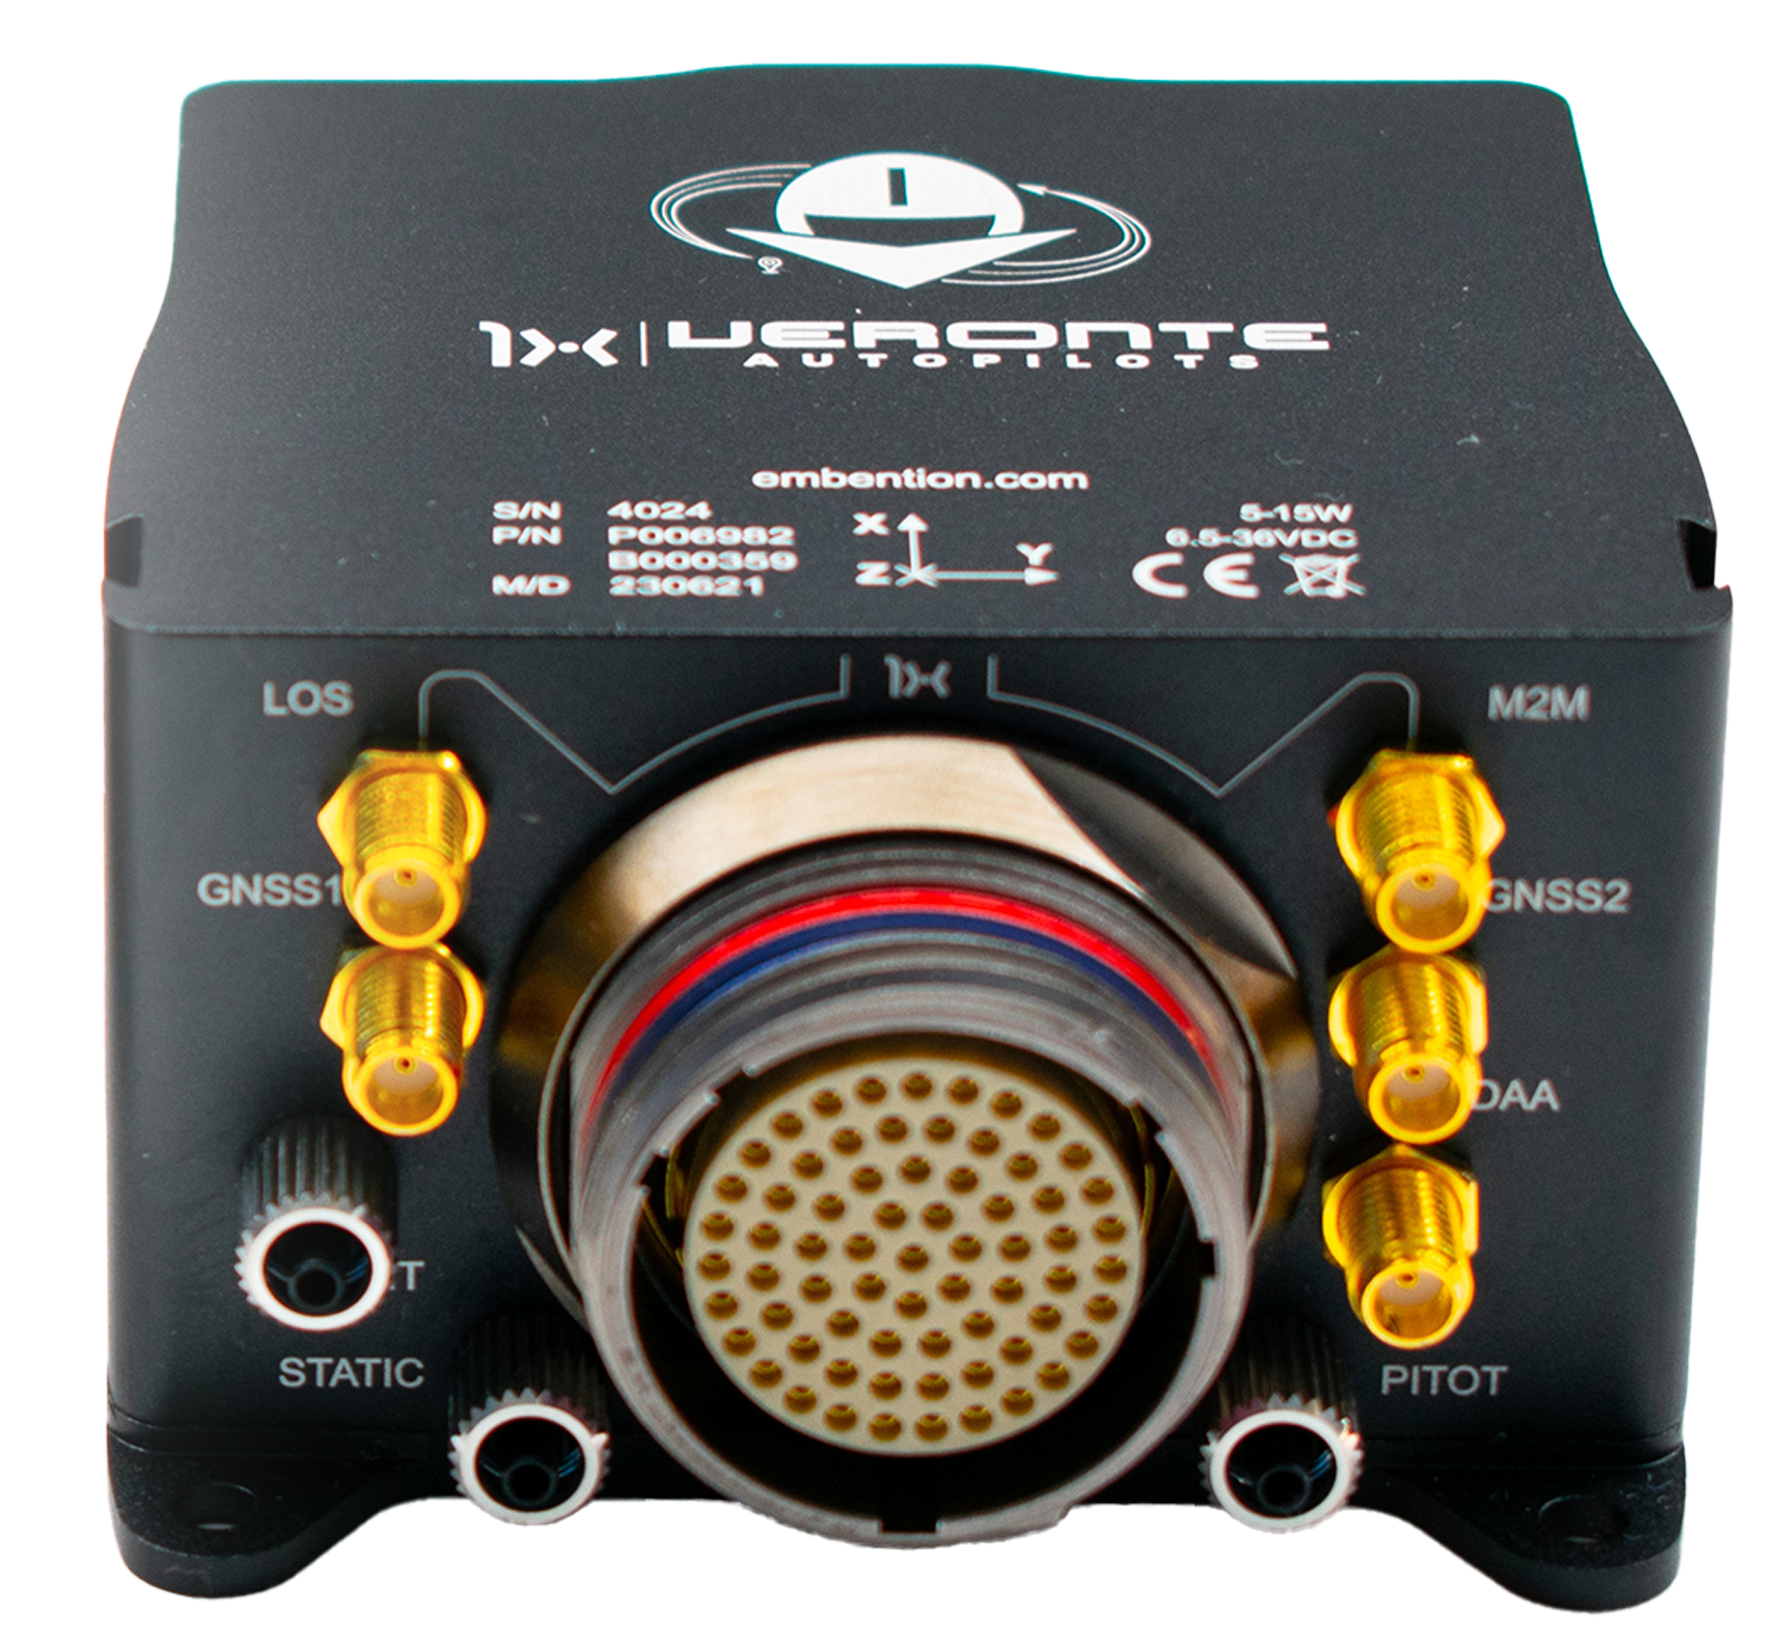
Veronte Avionics Mex, in addition to being a magnetometer, increases the number of devices in the system. MEX becomes a quick solution to increase connectivity capacity and allow for cabling optimization, especially in large systems.
I/O Expander Port
Mex increases the number of ports, adding RS232, PWM, RS485, I2C to Veronte Autopilot.
Data Concentrator
The redundant CAN bus increases data capacity by concentrating signals from other ports.
CAN Bus protection
In case of anomaly or malfunction, Mex will isolate the faulty devices from the bus.
Advanced Magnetic Compass
It uses magneto-inductive technology to measure the magnetic field in 3 axes.
EN BLANCO
Magneto Inductive Technology
Geomagnetic sensor technology offers high resolution, significant immunity to signal noise, wide dynamic range and high sampling rates.
Orientation in 3 Axes
The magnetic compass detects the direction and strength of a magnetic field, including the Earth’s magnetic field, to provide altitude and orientation references for any vehicle.
HMR2300 spare part
Veronte Avionics MEX is a direct replacement for Honeywell MHR-2300 through the serial port. It was widely used in drones and other autonomous vehicles.
Robust Performance
Redundant Communication
One of the advantages of Veronte MEX is the robustness of CAN Bus communications. It includes a redundant CAN Bus with galvanic isolation, so it can continue to operate and communicate with the autopilot even if a CAN Bus line is broken.
Fault Detection
The system incorporates algorithms for message filtering and detection of “chattering idiot faults”. Equipped with an integrated microcontroller, it performs real-time monitoring of the CAN Bus to be able to react quickly in case of anomalies or failures on the Bus.
Peripheral Isolation
The advanced control of actuators and peripherals becomes feasible, being possible to condense the connection of control, feedback, sensors… using several analog, digital, serial ports, etc. on a redundant CAN bus robust to failures and line breaks.
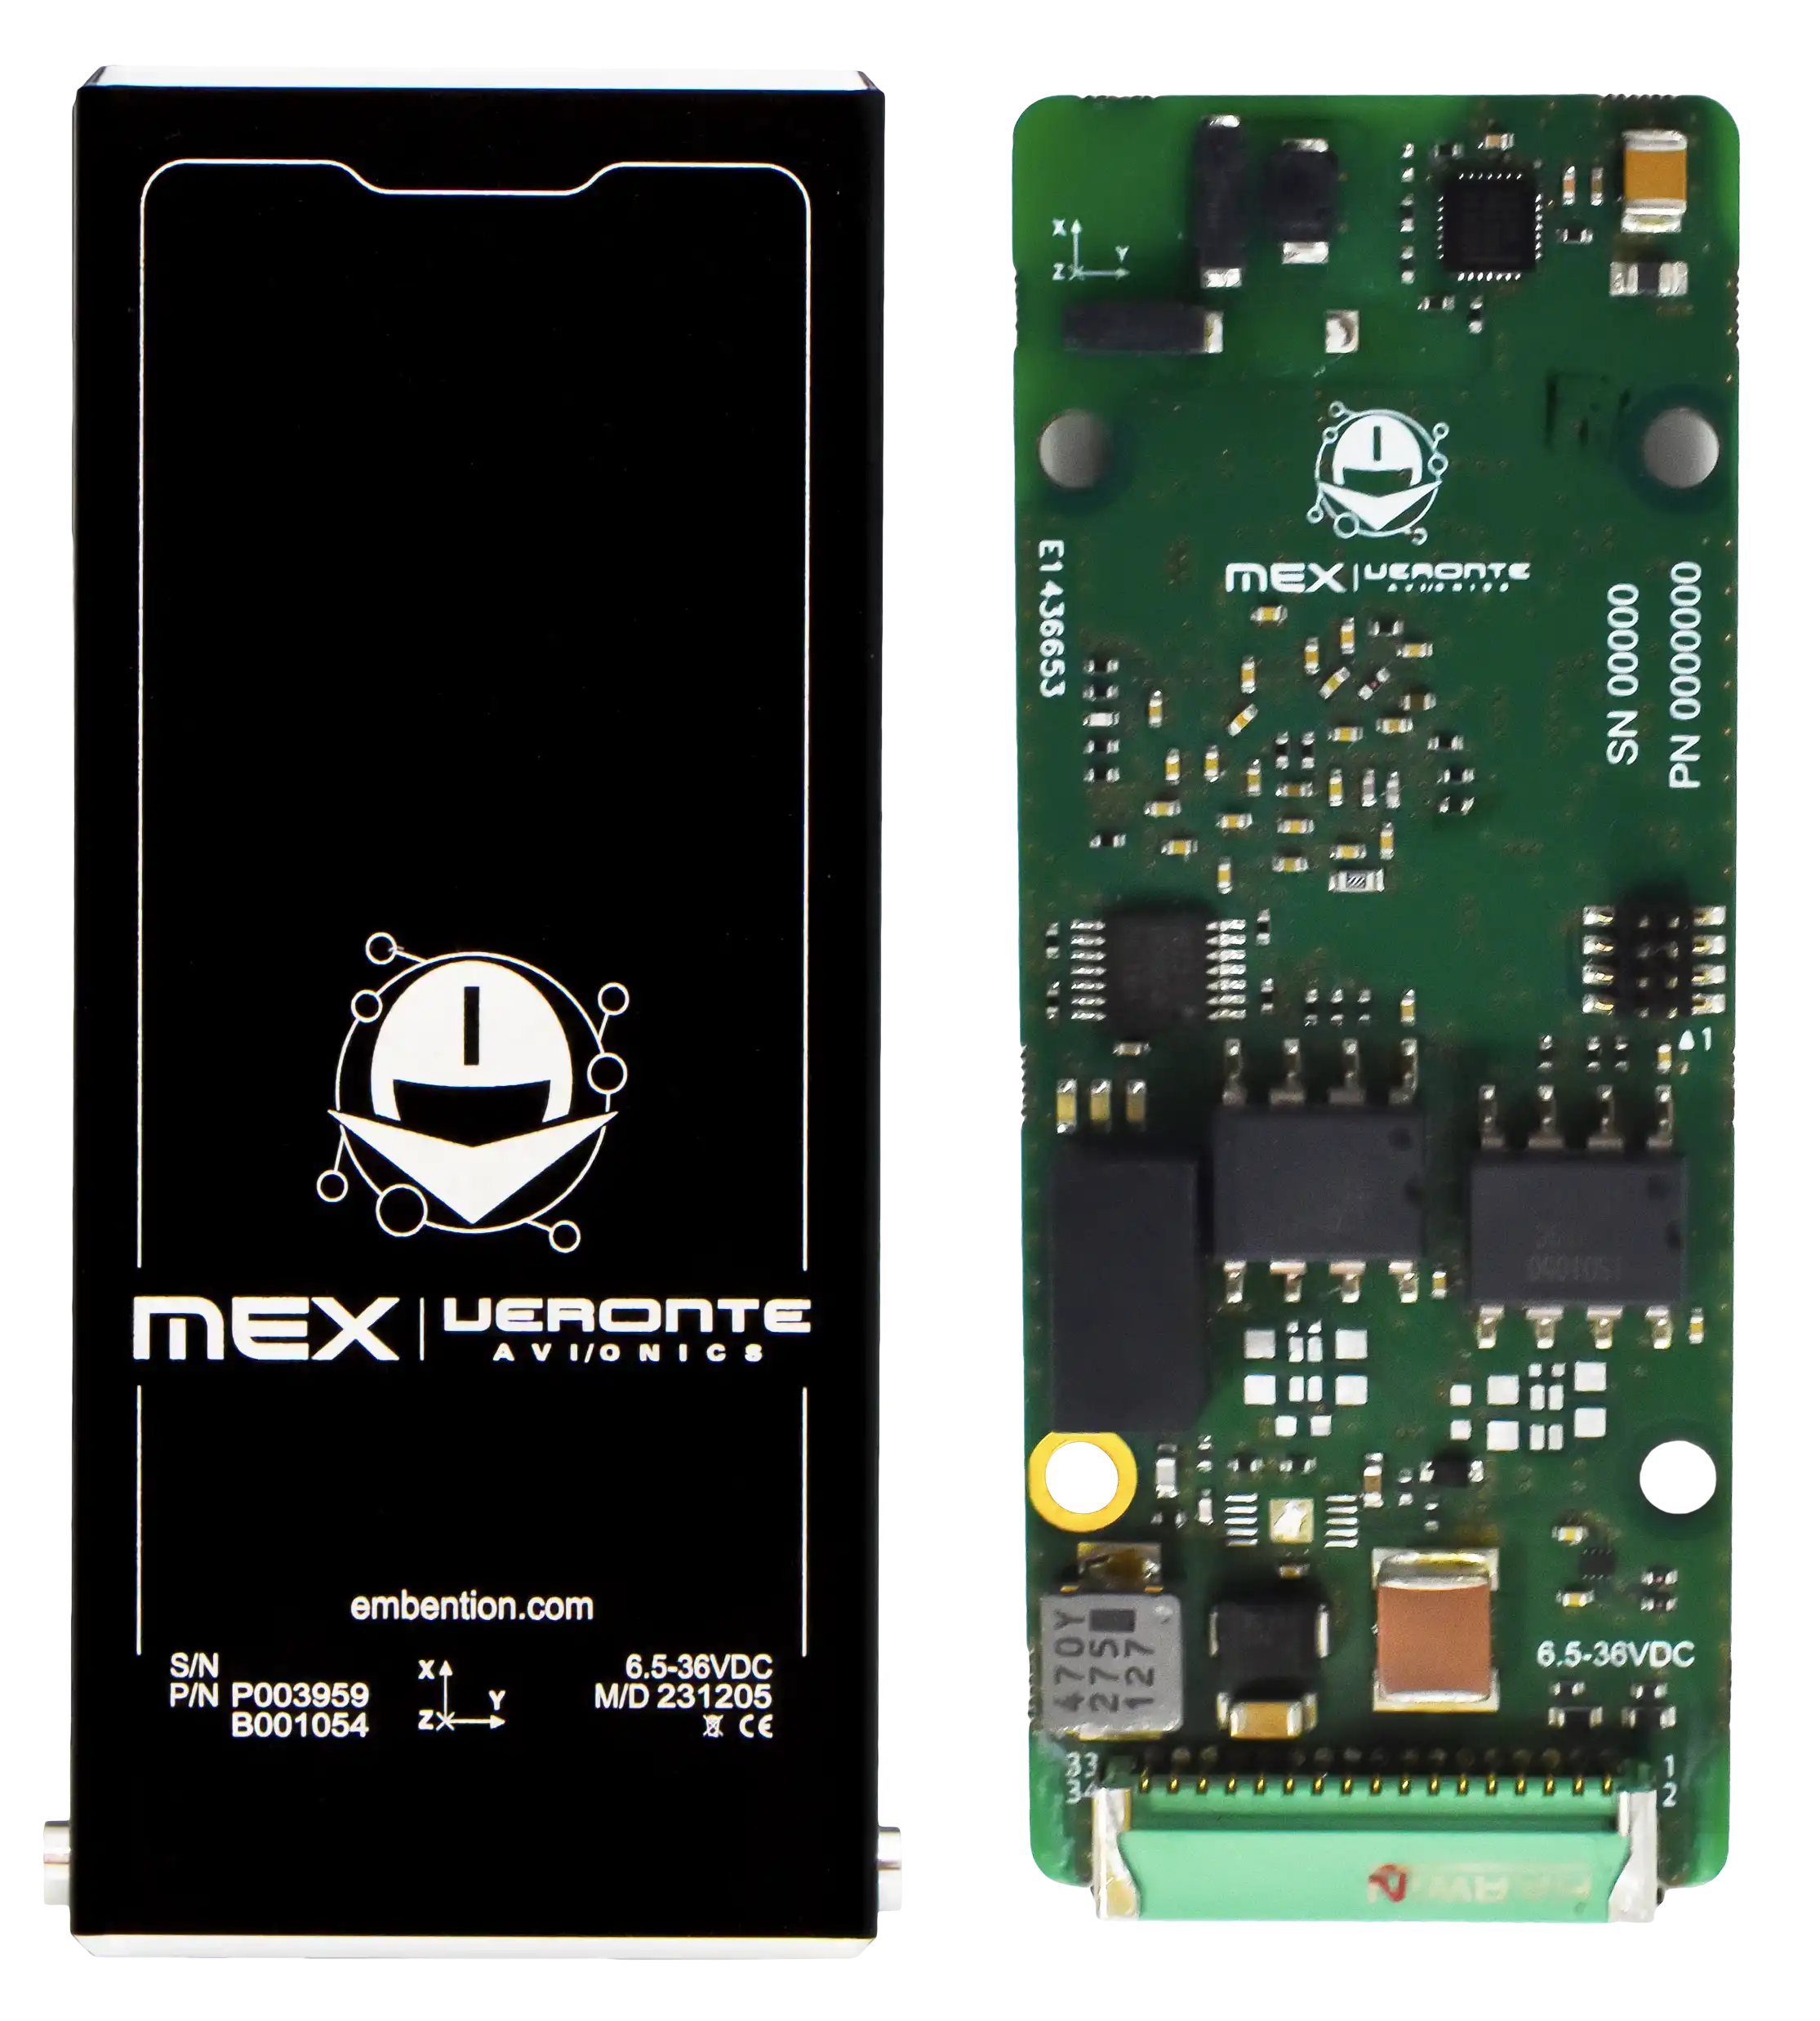
Robustness and Flexibility
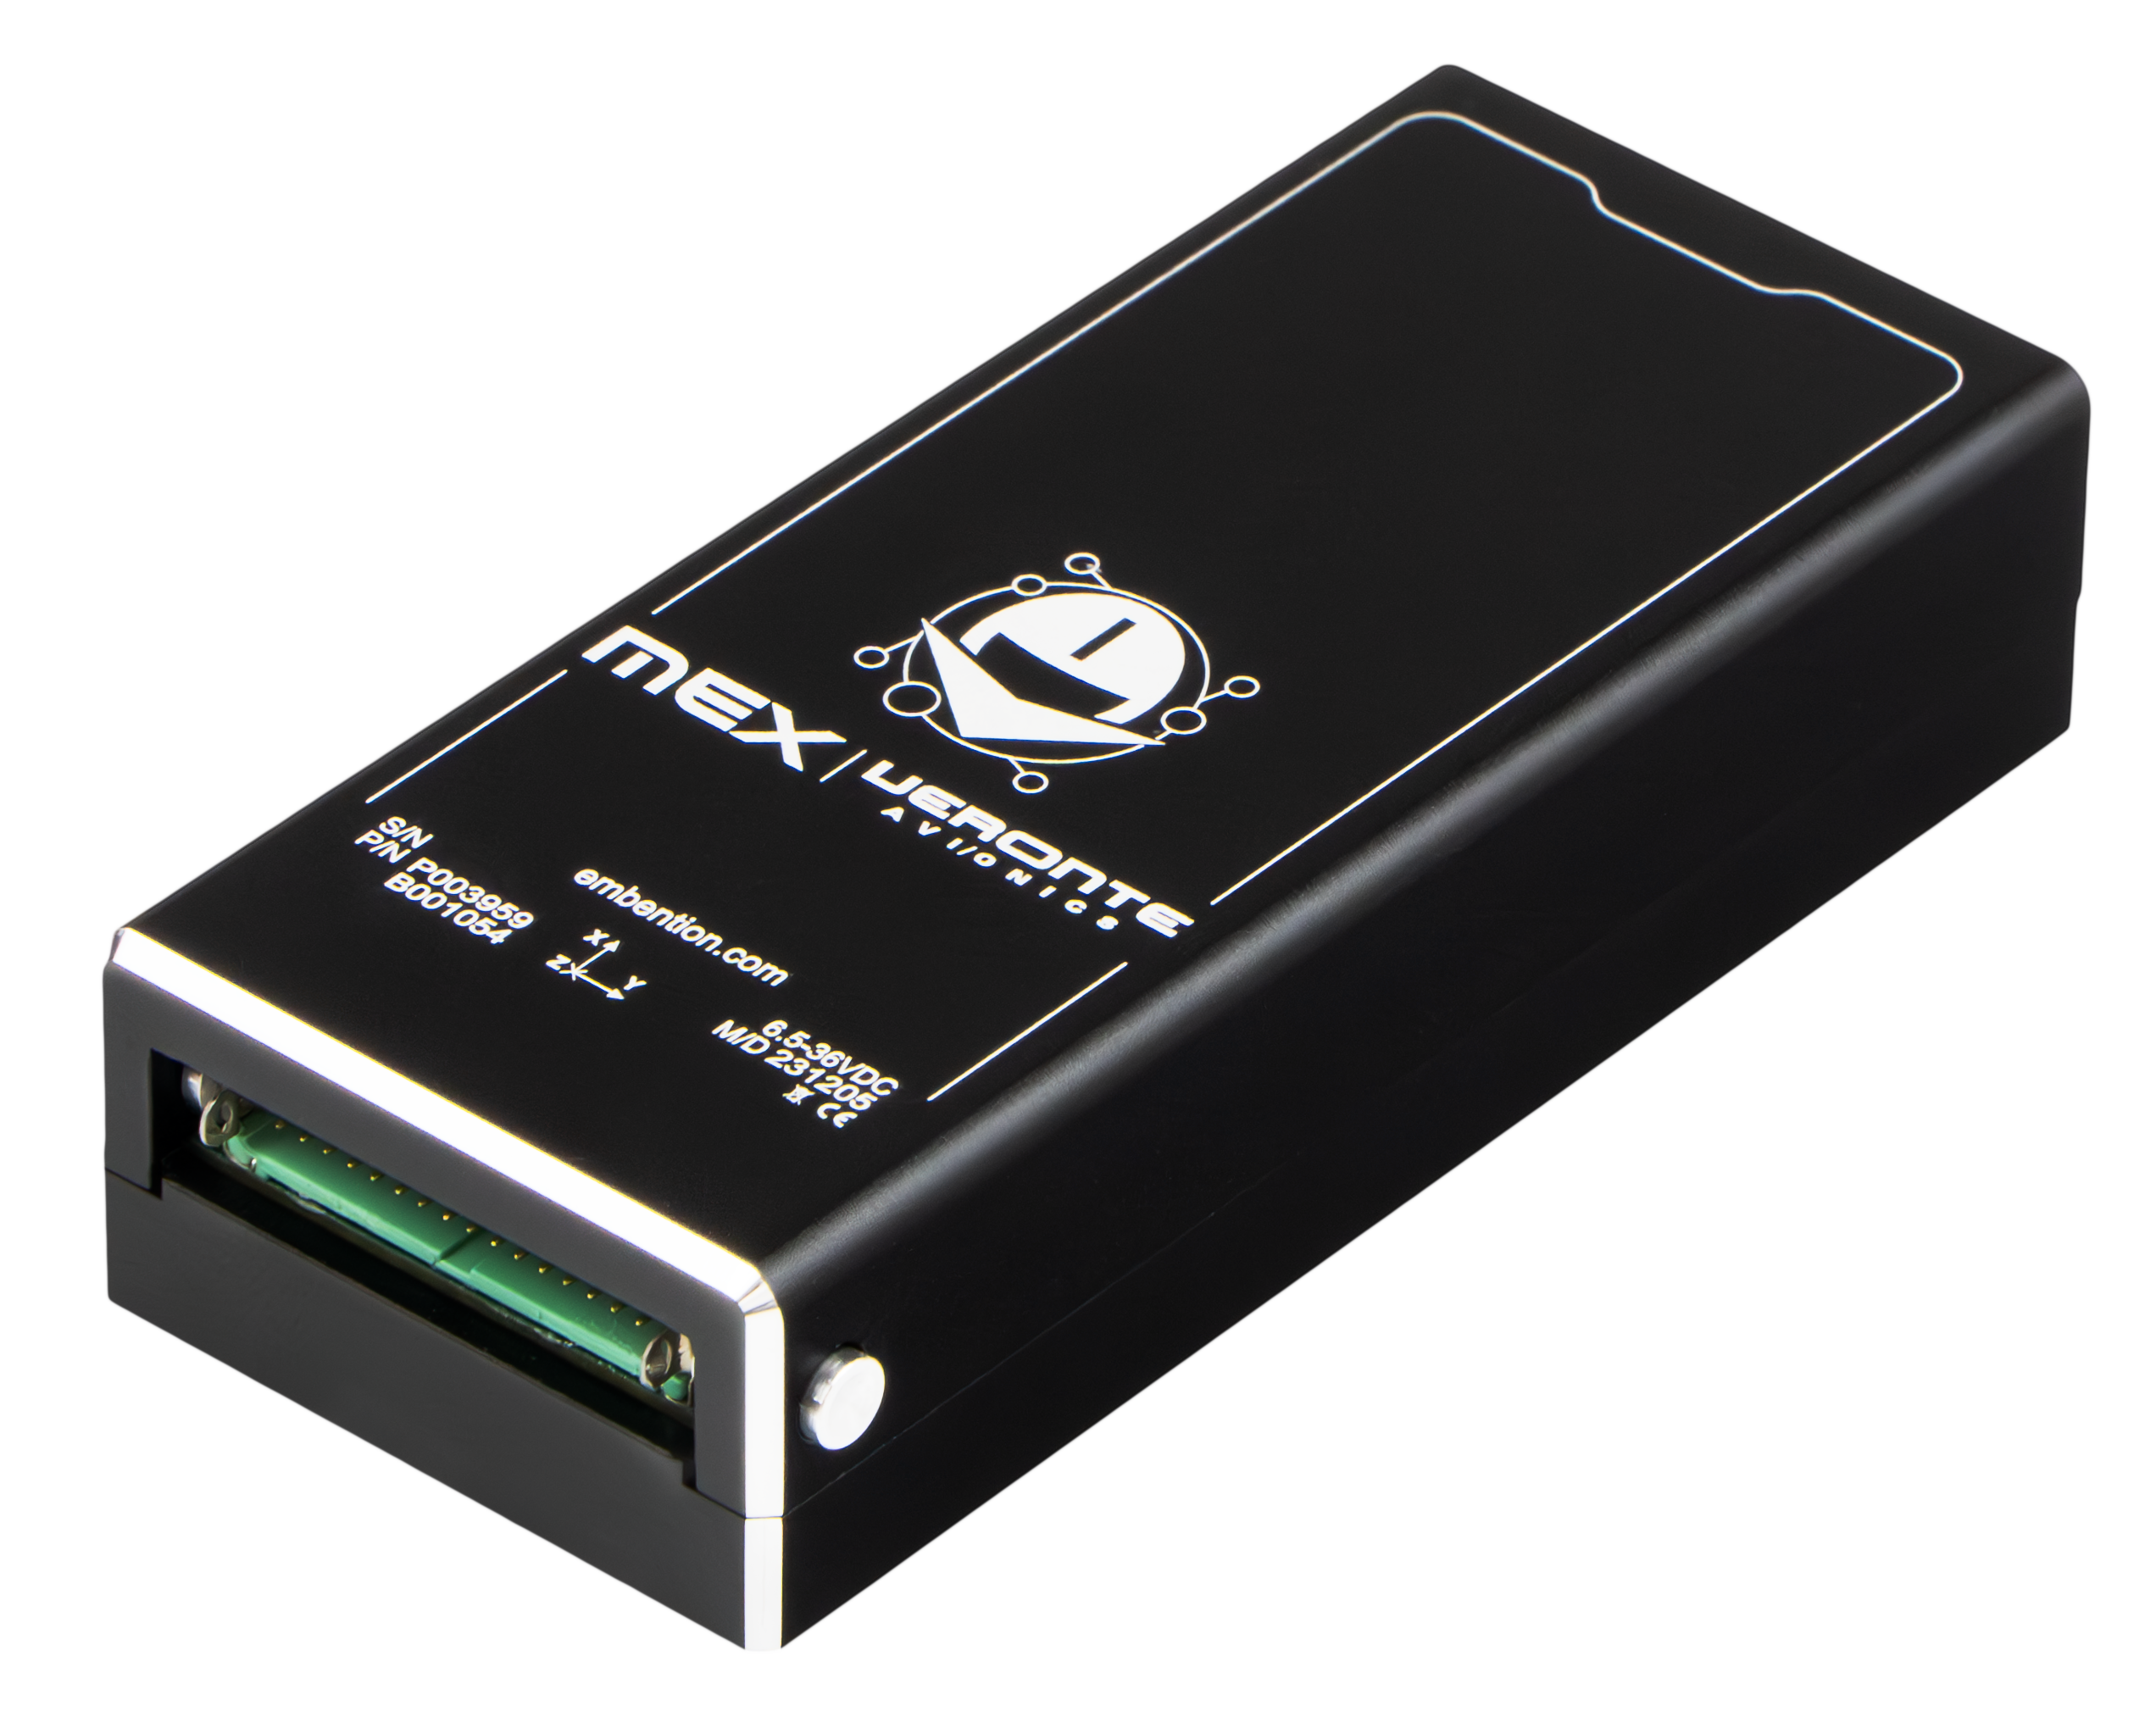
Offered in two different versions: Veronte MEX (protected by a 6061-T6 anodized aluminum housing) and Veronte MEX OEM (smaller and lighter, but requires mechanical protection when installed). Both versions feature reverse polarity protection, ESD protection and independent power supplies to ensure system robustness.
Certifiable
During the development of Veronte Avionics MEX, the aviation design standards DO178C / ED-12 and DO254 / ED 80 are followed. This allows to ensure hardware and software reliability for eVTOL and UAV certification, as well as for installation on critical autonomous vehicles. In addition, DO160 and MIL-STD-810 tests ensure robustness against adverse environmental conditions.
Specifications
| Vehicles | Plane | Multi | Heli | Others |
| 100% Autonomous | Mission & payload |
| Manual control | On pilot demand | Fly-by-camera |
| Embedded system | Sensors | GNC | Computer vision |
| Functionss | Autopilot | Vision navigation | Target follow |
| I/O ports | PWM | GPIO | Analog | CAN Bus | RS232 |
| Comunications | LOS | Satcom | Serial port |
| Autopilot | Fully autonomous flight control |
| GNSS Denied | Vision based navigtion |
| Target Identification | Target selection & follow |
| Terminal Impact | User selectable angle of impact |
| Payload Activation | Payload triggering | Safety mechanisms |
| Data Wipe | Onboard data erase prior to impact |
| Encryption | Data encryption |
| Single Use | Up to 25h operation |
| Programs | Model-based-design | Customization | PID level |
| Phases | Takeoff | Landing | Cruise | Impact | More |
| Automations | Failsafe | Phase change | Operation | Payload |
| Navigation | Sensor mix | Kalman filter | External sensors |
| Pheripherals | Gimbal | ADS-B | Altimeter | Cameras | Others |
| Compatibility | Custom protocols | Mission computer |
| Design Standards | Strict design standards | DO178-C | DO254 |
| Failsafe | Custom failsafe routines |
| Protections | ESD, Overtemperature, Short Circuit, RP |
| Reliability | ATR, DDP y DoD |
| Certification | ISO9001 Quality |
| Power Input | 6,5 – 36VDC |
| Temperature Range | -40 a 60ºC |
Price
| LM 1.0 | 4900€ |